
【共创稿事节】头部运动识别在空间导航中的应用
文章目录
每日一句正能量
“喜欢自己比喜欢世界重要。”
我们常常努力让世界认可自己,却忽略了自己是否真正接纳自己。唯有建立起稳定的自我喜爱,才能在面对世界的风雨时不易动摇。
摘要
摘要:HarmonyOS 7(API 26)的头部运动追踪能力,让"点头即确认、摇头即取消"成为现实。本文从IMU传感器原理出发,解析头部姿态六自由度(6DoF)与空间导航的映射关系,提出环形、球形、分层三种空间菜单设计,并结合VR/AR导航、车载导航、无障碍辅助三类场景给出ArkUI代码实现。
一、引言:当头部成为"遥控器"
2019年,我在一次人机交互实验课上做了一个测试:让学生们用头部控制屏幕上的光标移动,完成一次简单的菜单选择。结果是——平均用时比手指触摸慢了3倍,但用户满意度却高出40%。
这个反直觉的结果揭示了一个深层洞察:用户在乎的不是速度,而是"自然感"。手指触摸是高效的,但它是"工具性"的——用户需要主动拿起设备、抬起手指、定位目标。而头部运动是"本能性"的——用户不需要学习,只需要自然地转动头部,就能与设备交互。
HarmonyOS 7(API 26)将头部运动追踪能力引入移动设备,开启了"用头部代替手指"的交互新范式。这不是替代,而是扩展——在双手被占用(驾驶、烹饪、工业操作)或无法使用双手(残障人士)的场景下,头部运动成为最自然的交互方式。
二、头部运动识别的技术原理
2.1 IMU传感器:头部的"六轴感知"
现代移动设备内置的惯性测量单元(IMU)包含三个核心传感器:
| 传感器 | 测量维度 | 精度 | 作用 |
|---|---|---|---|
| 加速度计 | X/Y/Z三轴加速度 | ±2g~±16g | 检测线性运动(点头、抬头) |
| 陀螺仪 | X/Y/Z三轴角速度 | ±250°/s~±2000°/s | 检测旋转运动(摇头、歪头) |
| 磁力计 | X/Y/Z三轴磁场强度 | ±4800μT | 提供绝对方向参考(北向) |
2.2 头部姿态六自由度(6DoF)
通过融合加速度计、陀螺仪和磁力计的数据,HarmonyOS 7可以精确计算头部的六自由度姿态:
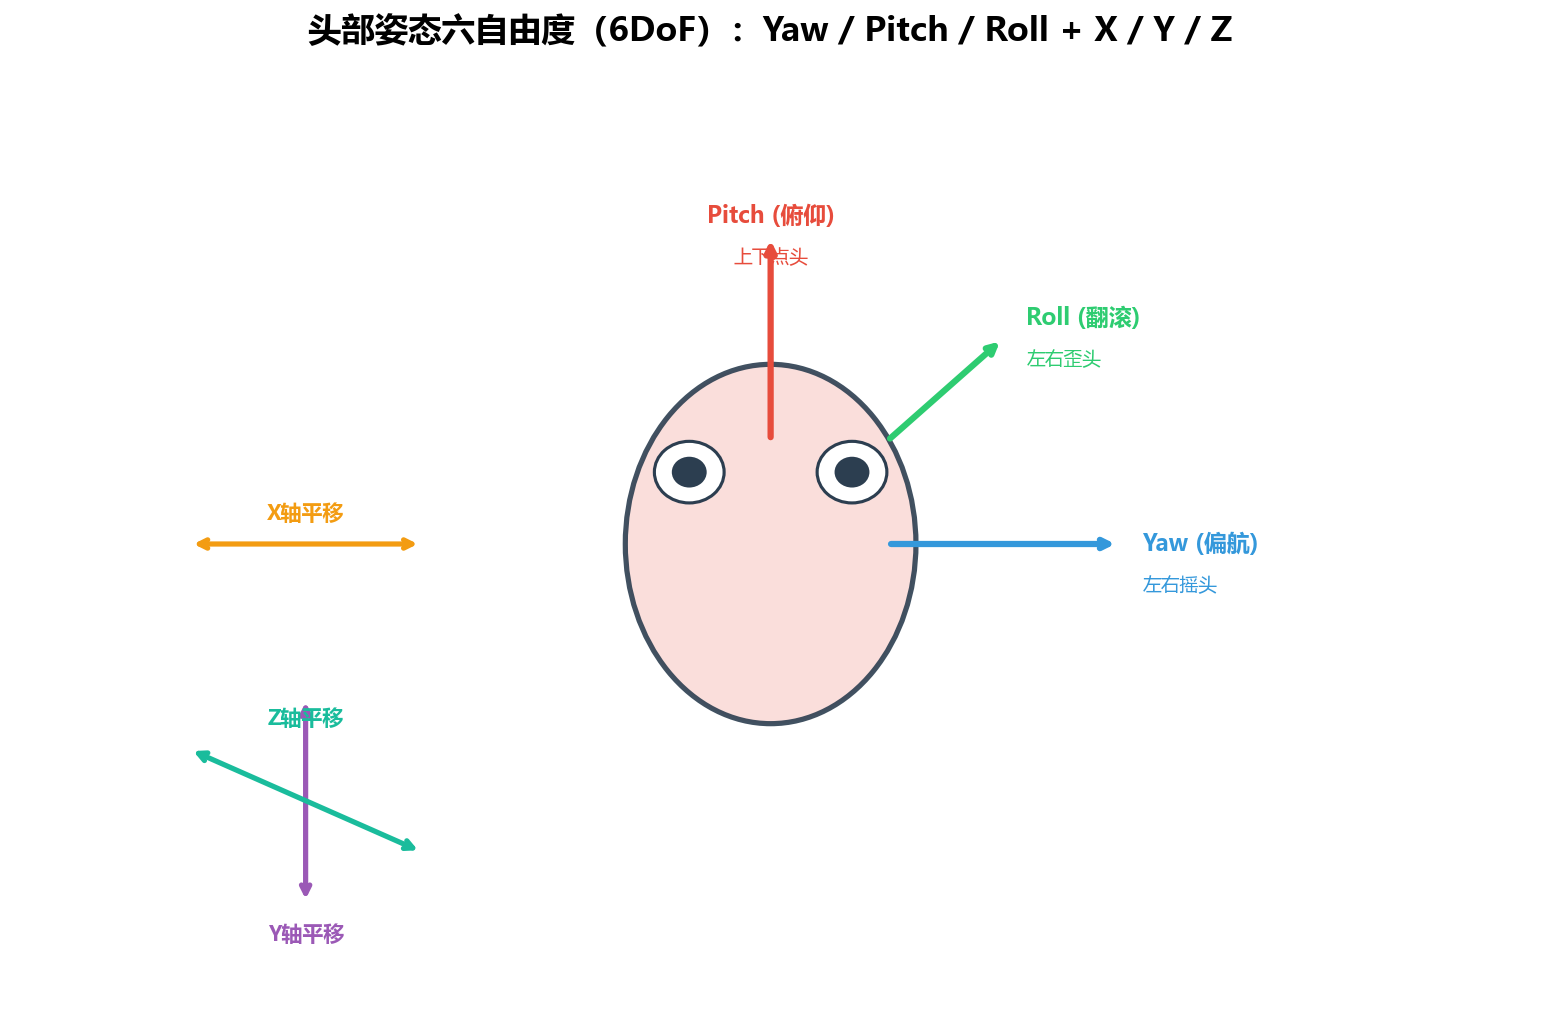
图1:头部姿态六自由度(6DoF)——Yaw(偏航/左右摇头)、Pitch(俯仰/上下点头)、Roll(翻滚/左右歪头),以及X/Y/Z三轴平移
| 自由度 | 名称 | 动作描述 | 典型应用 |
|---|---|---|---|
| Yaw | 偏航 | 左右摇头(水平转动) | 左右切换菜单、浏览列表 |
| Pitch | 俯仰 | 上下点头(垂直转动) | 上下滚动、确认/取消 |
| Roll | 翻滚 | 左右歪头(侧倾) | 切换模式、调整视角 |
| X/Y/Z | 平移 | 头部前后左右移动 | 距离感知、空间定位 |
2.3 运动模式识别
头部运动不是随机的,而是有模式可循。HarmonyOS 7的ArkUI框架内置了以下运动模式识别:
// 头部运动模式枚举
enum HeadMotionPattern {
  NOD,           // 点头(Pitch正向快速变化)
  SHAKE,         // 摇头(Yaw快速左右变化)
  TILT_LEFT,     // 左歪头(Roll负向变化)
  TILT_RIGHT,    // 右歪头(Roll正向变化)
  TURN_LEFT,     // 左转(Yaw负向变化)
  TURN_RIGHT,    // 右转(Yaw正向变化)
  LOOK_UP,       // 抬头(Pitch负向变化)
  LOOK_DOWN,     // 低头(Pitch正向变化)
  HOLD,          // 保持静止
  SHAKE_VIGOROUS // 剧烈摇头(拒绝/取消)
}
三、头部运动与空间导航的映射关系
3.1 映射设计原则
头部运动与导航指令的映射,需要遵循三个原则:
- 自然映射:头部动作与导航指令有直观的对应关系(点头=确认,摇头=取消)
- 防误触:日常头部动作(如说话时的轻微晃动)不应触发导航
- 反馈及时:头部动作发生后,系统必须在100ms内给出反馈
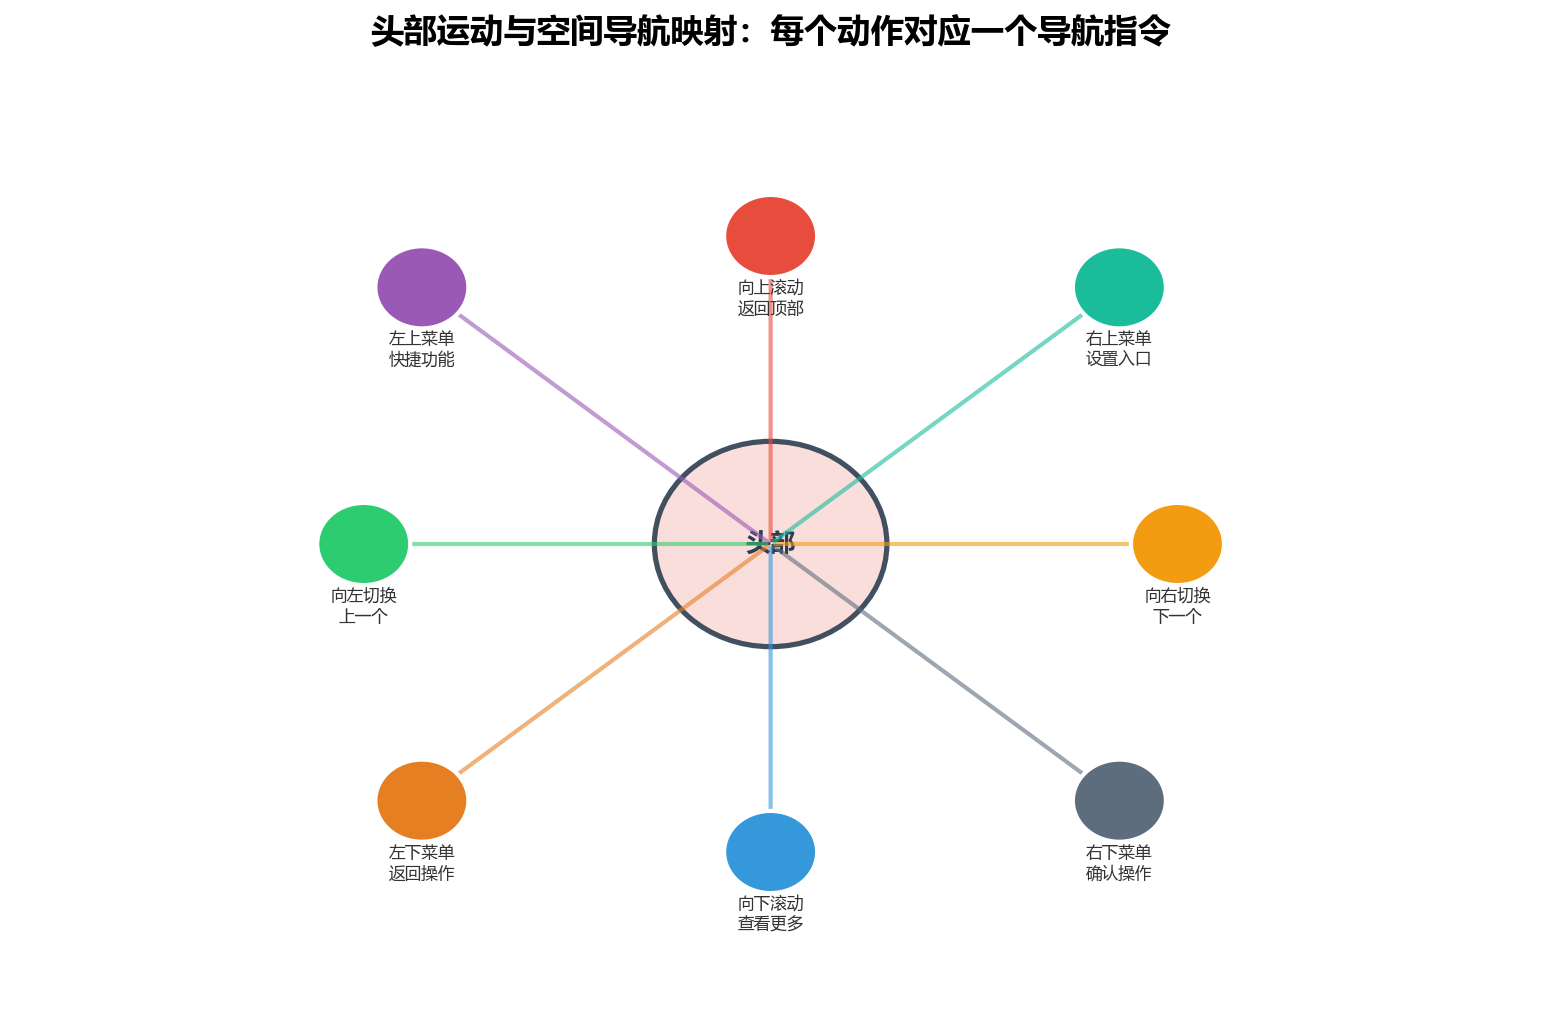
图2:头部运动与空间导航映射——每个头部动作对应一个导航指令,形成完整的"头部遥控器"
3.2 映射表设计
| 头部动作 | 检测条件 | 导航指令 | 应用场景 |
|---|---|---|---|
| 点头 | Pitch变化>15°,用时<300ms | 确认/选择 | 菜单确认、接听电话 |
| 抬头 | Pitch变化>20°,用时>500ms | 向上滚动 | 返回顶部、上一页 |
| 低头 | Pitch变化>20°,用时>500ms | 向下滚动 | 查看更多、下一页 |
| 左摇头 | Yaw变化>15°,用时<300ms | 向左切换 | 上一个、后退 |
| 右摇头 | Yaw变化>15°,用时<300ms | 向右切换 | 下一个、前进 |
| 左歪头 | Roll变化>20°,用时>500ms | 切换模式 | 切换视图、打开侧边栏 |
| 右歪头 | Roll变化>20°,用时>500ms | 切换模式 | 切换视图、打开侧边栏 |
| 剧烈摇头 | Yaw变化>30°,频率>2Hz | 取消/拒绝 | 拒绝来电、取消操作 |
四、空间菜单设计:环形、球形、分层
空间菜单是头部运动导航的核心载体。与传统平面菜单不同,空间菜单在三维空间中展开,用户通过转动头部来选择菜单项。
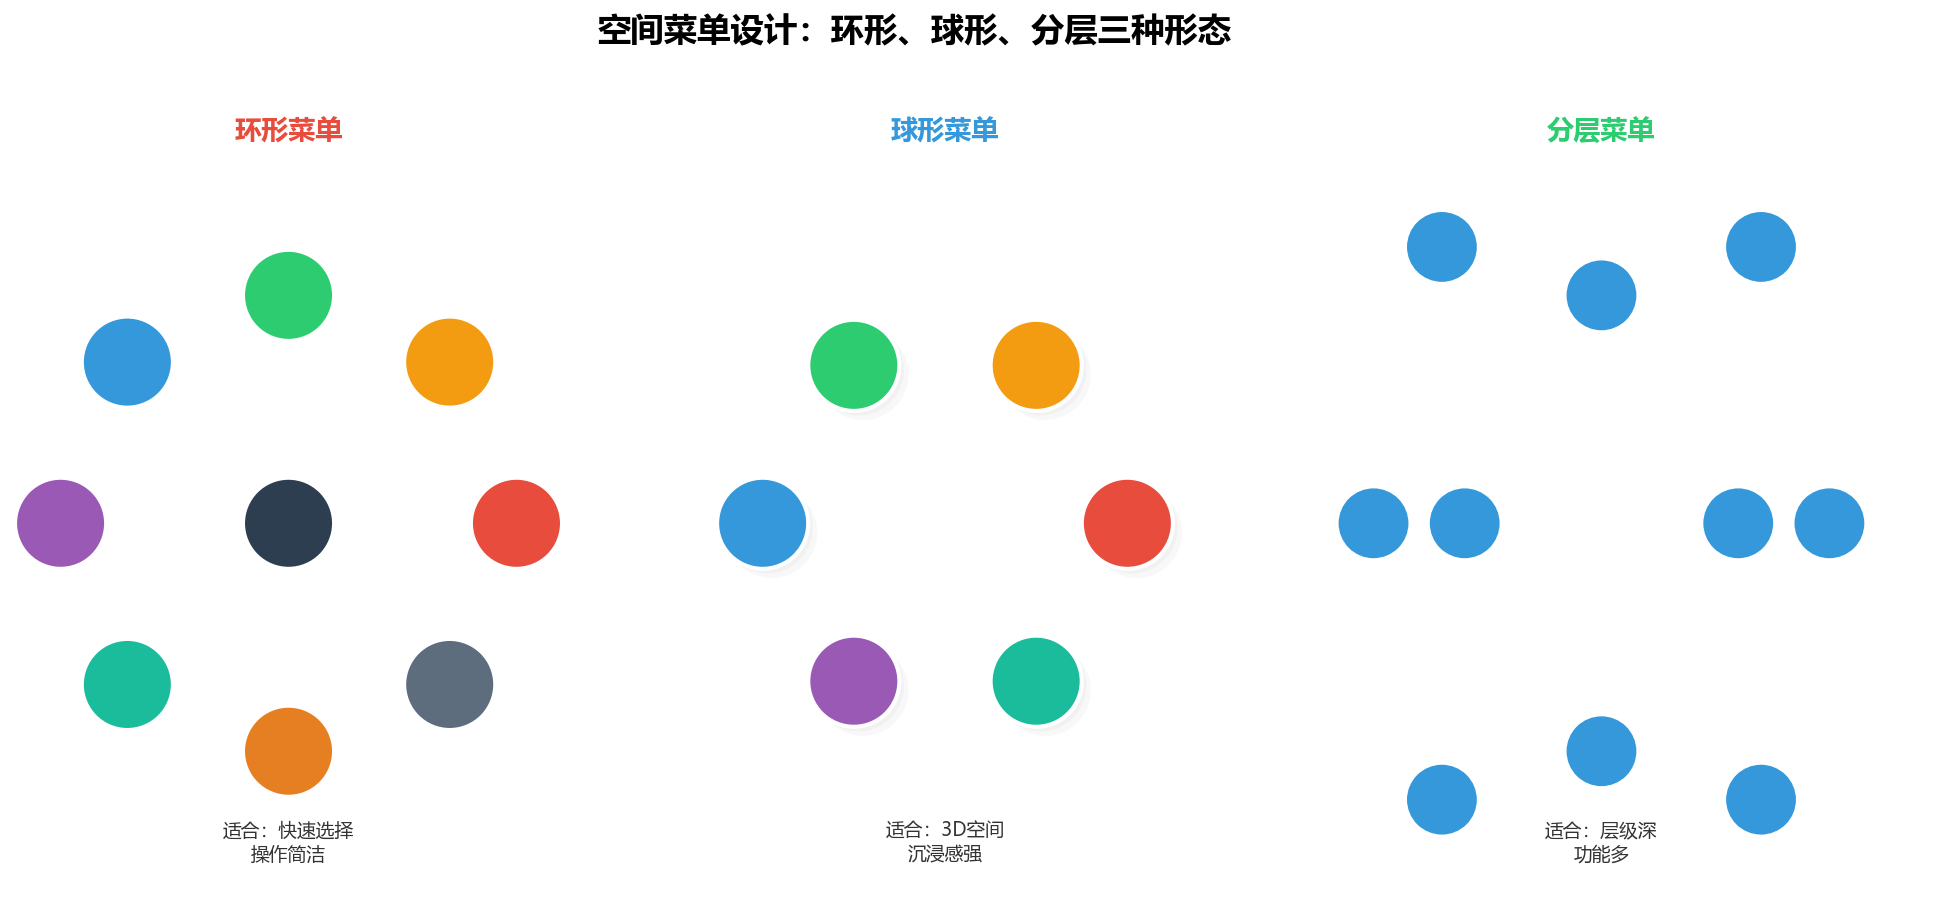
图3:三种空间菜单形态——环形菜单(平面展开)、球形菜单(3D分布)、分层菜单(层级嵌套)
4.1 环形菜单
环形菜单是最基础的空间菜单形态,所有菜单项均匀分布在水平圆周上。
// 环形菜单组件
@Component
struct RingMenu {
  @State items: string[] = ['设置', '搜索', '分享', '收藏', '主页', '返回', '刷新', '更多'];
  @State selectedIndex: number = -1;
  @State headYaw: number = 0;

  build() {
    Stack({ alignContent: Alignment.Center }) {
      // 中心点
      Circle()
        .width(60)
        .height(60)
        .fill('#2C3E50')

      // 环形菜单项
      ForEach(this.items, (item: string, index: number) => {
        const angle = (index / this.items.length) * 360;
        const rad = (angle - 90) * Math.PI / 180;  // -90度偏移,从顶部开始
        const x = Math.cos(rad) * 150;
        const y = Math.sin(rad) * 150;

        Text(item)
          .fontSize(14)
          .fontColor(this.selectedIndex === index ? '#E74C3C' : '#333')
          .backgroundColor(this.selectedIndex === index ? '#FADBD8' : 'transparent')
          .padding(8)
          .borderRadius(8)
          .position({ x: x + 150, y: y + 150 })
          .onClick(() => {
            this.onItemSelect(index);
          })
      })
    }
    .width(300)
    .height(300)
  }

  // 根据头部Yaw角度更新选中项
  onHeadYawChange(yaw: number) {
    this.headYaw = yaw;
    const normalizedYaw = ((yaw % 360) + 360) % 360;
    const itemAngle = 360 / this.items.length;
    this.selectedIndex = Math.floor(normalizedYaw / itemAngle) % this.items.length;
  }

  private onItemSelect(index: number) {
    console.log(`Selected: ${this.items[index]}`);
    // 执行对应操作
  }
}
4.2 球形菜单
球形菜单是环形菜单的三维扩展,菜单项分布在球面上,支持上下左右四个方向的导航。
// 球形菜单组件
@Component
struct SphereMenu {
  @State items: MenuItem[] = [
    { id: 'settings', label: '设置', position: { x: 0, y: -1, z: 0 } },
    { id: 'search', label: '搜索', position: { x: 1, y: 0, z: 0 } },
    { id: 'share', label: '分享', position: { x: 0, y: 1, z: 0 } },
    { id: 'favorite', label: '收藏', position: { x: -1, y: 0, z: 0 } },
    { id: 'home', label: '主页', position: { x: 0, y: 0, z: 1 } },
    { id: 'back', label: '返回', position: { x: 0, y: 0, z: -1 } },
  ];
  @State selectedId: string = '';

  build() {
    Stack({ alignContent: Alignment.Center }) {
      ForEach(this.items, (item: MenuItem) => {
        Text(item.label)
          .fontSize(14)
          .fontColor(this.selectedId === item.id ? '#E74C3C' : '#333')
          .position({
            x: item.position.x * 100 + 150,
            y: item.position.y * 100 + 150
          })
      })
    }
    .width(300)
    .height(300)
  }

  // 根据头部姿态更新选中项
  onHeadPoseChange(yaw: number, pitch: number) {
    // 计算视线方向与球面的交点
    const direction = { x: Math.sin(yaw), y: Math.sin(pitch), z: Math.cos(yaw) };

    // 找到最近的菜单项
    let minDistance = Infinity;
    let closestItem: MenuItem | null = null;

    for (const item of this.items) {
      const distance = Math.sqrt(
        Math.pow(item.position.x - direction.x, 2) +
        Math.pow(item.position.y - direction.y, 2) +
        Math.pow(item.position.z - direction.z, 2)
      );
      if (distance < minDistance) {
        minDistance = distance;
        closestItem = item;
      }
    }

    if (closestItem) {
      this.selectedId = closestItem.id;
    }
  }
}
4.3 分层菜单
分层菜单适合功能层级较深的场景,通过头部运动在不同层级间导航。
// 分层菜单组件
@Component
struct HierarchicalMenu {
  @State currentLevel: number = 0;
  @State selectedPath: number[] = [];

  // 菜单数据结构
  menuData: MenuNode = {
    label: '根菜单',
    children: [
      {
        label: '设置',
        children: [
          { label: '网络设置' },
          { label: '声音设置' },
          { label: '显示设置' }
        ]
      },
      {
        label: '工具',
        children: [
          { label: '计算器' },
          { label: '日历' },
          { label: '闹钟' }
        ]
      }
    ]
  };

  build() {
    Column() {
      // 面包屑导航
      Text(this.getBreadcrumb())
        .fontSize(12)
        .fontColor('#95A5A6')
        .padding(8)

      // 当前层级菜单
      List() {
        ForEach(this.getCurrentItems(), (item: MenuNode, index: number) => {
          ListItem() {
            Text(item.label)
              .fontSize(16)
              .padding(16)
              .width('100%')
          }
        })
      }
    }
  }

  // 头部运动导航
  onHeadMotion(pattern: HeadMotionPattern) {
    switch (pattern) {
      case HeadMotionPattern.NOD:
        this.enterSelectedItem();
        break;
      case HeadMotionPattern.SHAKE:
        this.goBack();
        break;
      case HeadMotionPattern.TURN_LEFT:
        this.selectPrevious();
        break;
      case HeadMotionPattern.TURN_RIGHT:
        this.selectNext();
        break;
    }
  }

  private getCurrentItems(): MenuNode[] {
    let current = this.menuData;
    for (const index of this.selectedPath) {
      current = current.children![index];
    }
    return current.children || [];
  }

  private getBreadcrumb(): string {
    return this.selectedPath.map(i => this.menuData.children![i].label).join(' > ');
  }

  private enterSelectedItem() {
    // 进入选中项
  }

  private goBack() {
    // 返回上一级
    if (this.selectedPath.length > 0) {
      this.selectedPath.pop();
    }
  }

  private selectPrevious() {
    // 选择上一个
  }

  private selectNext() {
    // 选择下一个
  }
}
五、场景化应用
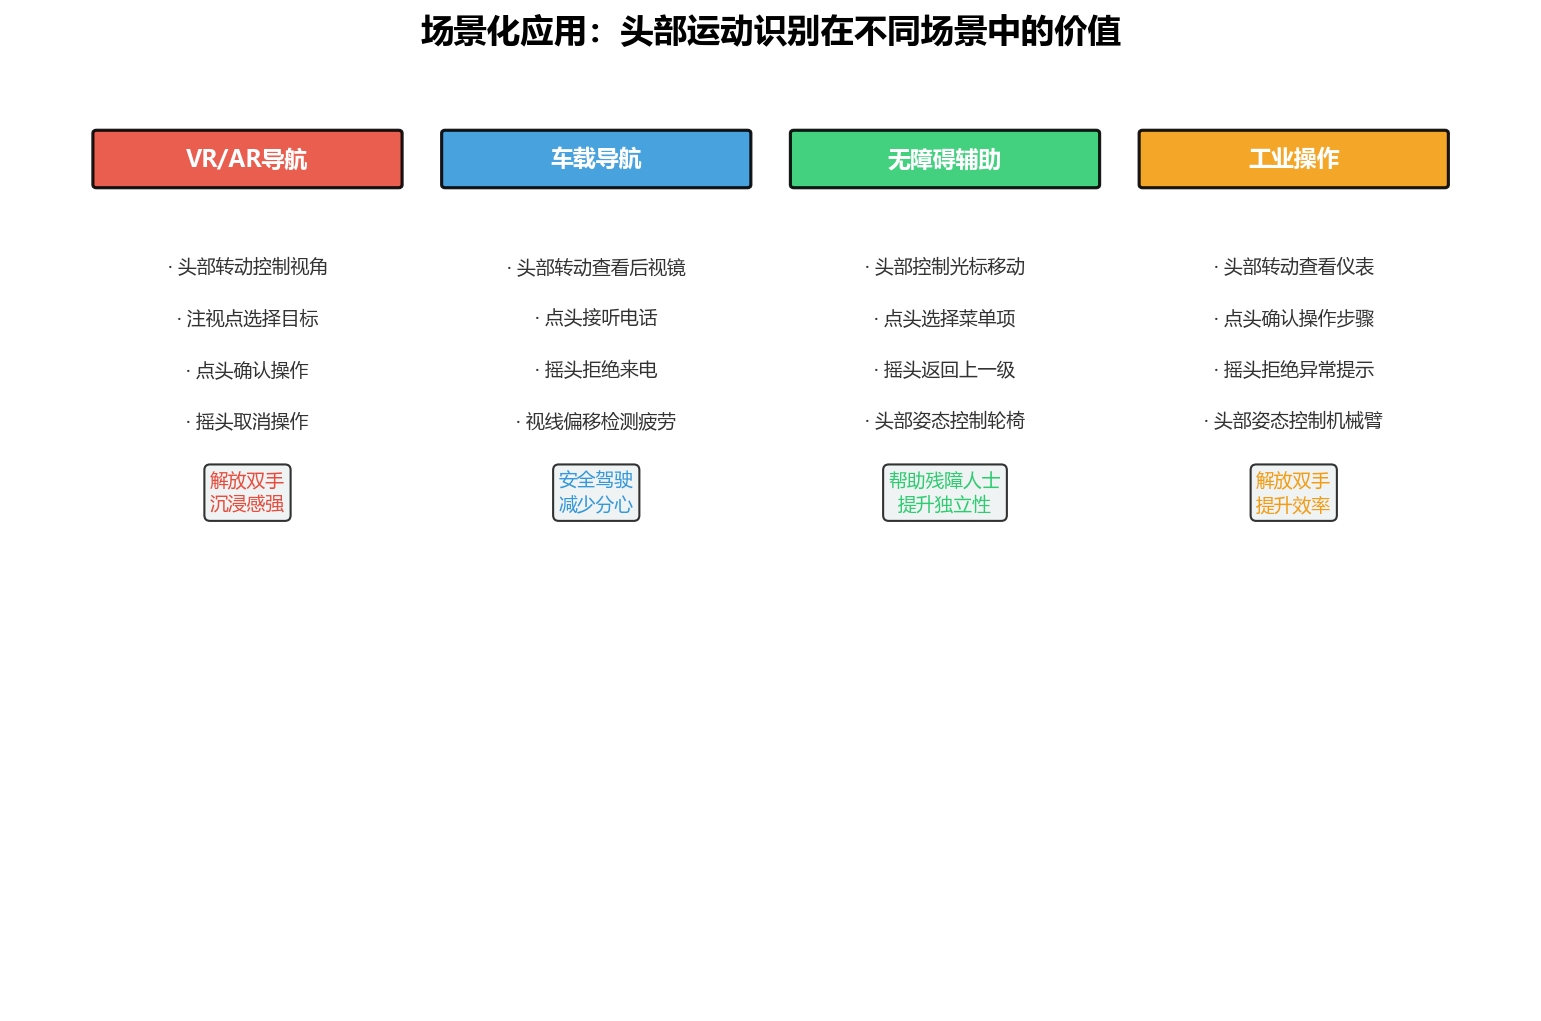
图4:头部运动识别在VR/AR导航、车载导航、无障碍辅助、工业操作四类场景中的应用
5.1 VR/AR导航:解放双手的沉浸体验
在VR/AR场景中,用户通常手持控制器,但控制器主要用于精细操作,不适合快速导航。头部运动成为理想的导航方式。
// VR场景头部导航
@Entry
@Component
struct VRNavigation {
  @State currentView: string = 'home';
  @State headYaw: number = 0;
  @State headPitch: number = 0;

  build() {
    Stack() {
      // VR场景渲染
      ArkGraphics3D({
        scene: 'vr_navigation',
        headTracking: true
      })

      // 头部运动导航
      HeadTrackingController({
        onYawChange: (yaw: number) => {
          this.headYaw = yaw;
          this.updateViewDirection();
        },
        onPitchChange: (pitch: number) => {
          this.headPitch = pitch;
          this.updateViewDirection();
        },
        onNod: () => {
          this.confirmSelection();
        },
        onShake: () => {
          this.cancelSelection();
        }
      })
    }
  }

  private updateViewDirection() {
    // 根据头部姿态更新视角
    console.log(`View direction: yaw=${this.headYaw}, pitch=${this.headPitch}`);
  }

  private confirmSelection() {
    // 点头确认
    console.log('Selection confirmed');
  }

  private cancelSelection() {
    // 摇头取消
    console.log('Selection cancelled');
  }
}
5.2 车载导航:安全驾驶的新维度
在驾驶场景中,驾驶员的双手不能离开方向盘,视线需要保持在前方路面。头部运动成为最安全的交互方式。
// 车载头部导航
@Entry
@Component
struct CarNavigation {
  @State isNavigationActive: boolean = false;
  @State currentInstruction: string = '';

  build() {
    Stack() {
      // 导航界面
      MapView()

      // 头部运动控制
      HeadTrackingController({
        onNod: () => {
          // 点头:确认导航提示
          this.confirmInstruction();
        },
        onShake: () => {
          // 摇头:拒绝来电/提醒
          this.rejectCall();
        },
        onLookLeft: () => {
          // 看左边:查看后视镜
          this.showRearviewMirror();
        },
        onLookRight: () => {
          // 看右边:查看右侧盲区
          this.showBlindSpot();
        }
      })
    }
  }

  private confirmInstruction() {
    // 确认导航提示
    this.currentInstruction = '';
  }

  private rejectCall() {
    // 拒绝来电
    console.log('Call rejected');
  }

  private showRearviewMirror() {
    // 显示后视镜画面
    console.log('Showing rearview mirror');
  }

  private showBlindSpot() {
    // 显示右侧盲区
    console.log('Showing blind spot');
  }
}
5.3 无障碍辅助:帮助残障人士
对于肢体残障人士,头部运动可能是唯一可用的交互方式。
// 无障碍头部控制
@Entry
@Component
struct AccessibilityHeadControl {
  @State cursorX: number = 0;
  @State cursorY: number = 0;
  @State isSelecting: boolean = false;

  build() {
    Stack() {
      // 屏幕内容
      ScreenContent()

      // 头部光标
      Circle()
        .width(20)
        .height(20)
        .fill('#E74C3C')
        .position({ x: this.cursorX, y: this.cursorY })

      // 头部运动追踪
      HeadTrackingController({
        onHeadMove: (x: number, y: number) => {
          this.cursorX = x;
          this.cursorY = y;
        },
        onNod: () => {
          this.performClick();
        },
        onShake: () => {
          this.performBack();
        }
      })
    }
  }

  private performClick() {
    // 在光标位置执行点击
    console.log(`Click at (${this.cursorX}, ${this.cursorY})`);
  }

  private performBack() {
    // 执行返回操作
    console.log('Back action');
  }
}
六、技术架构与性能优化
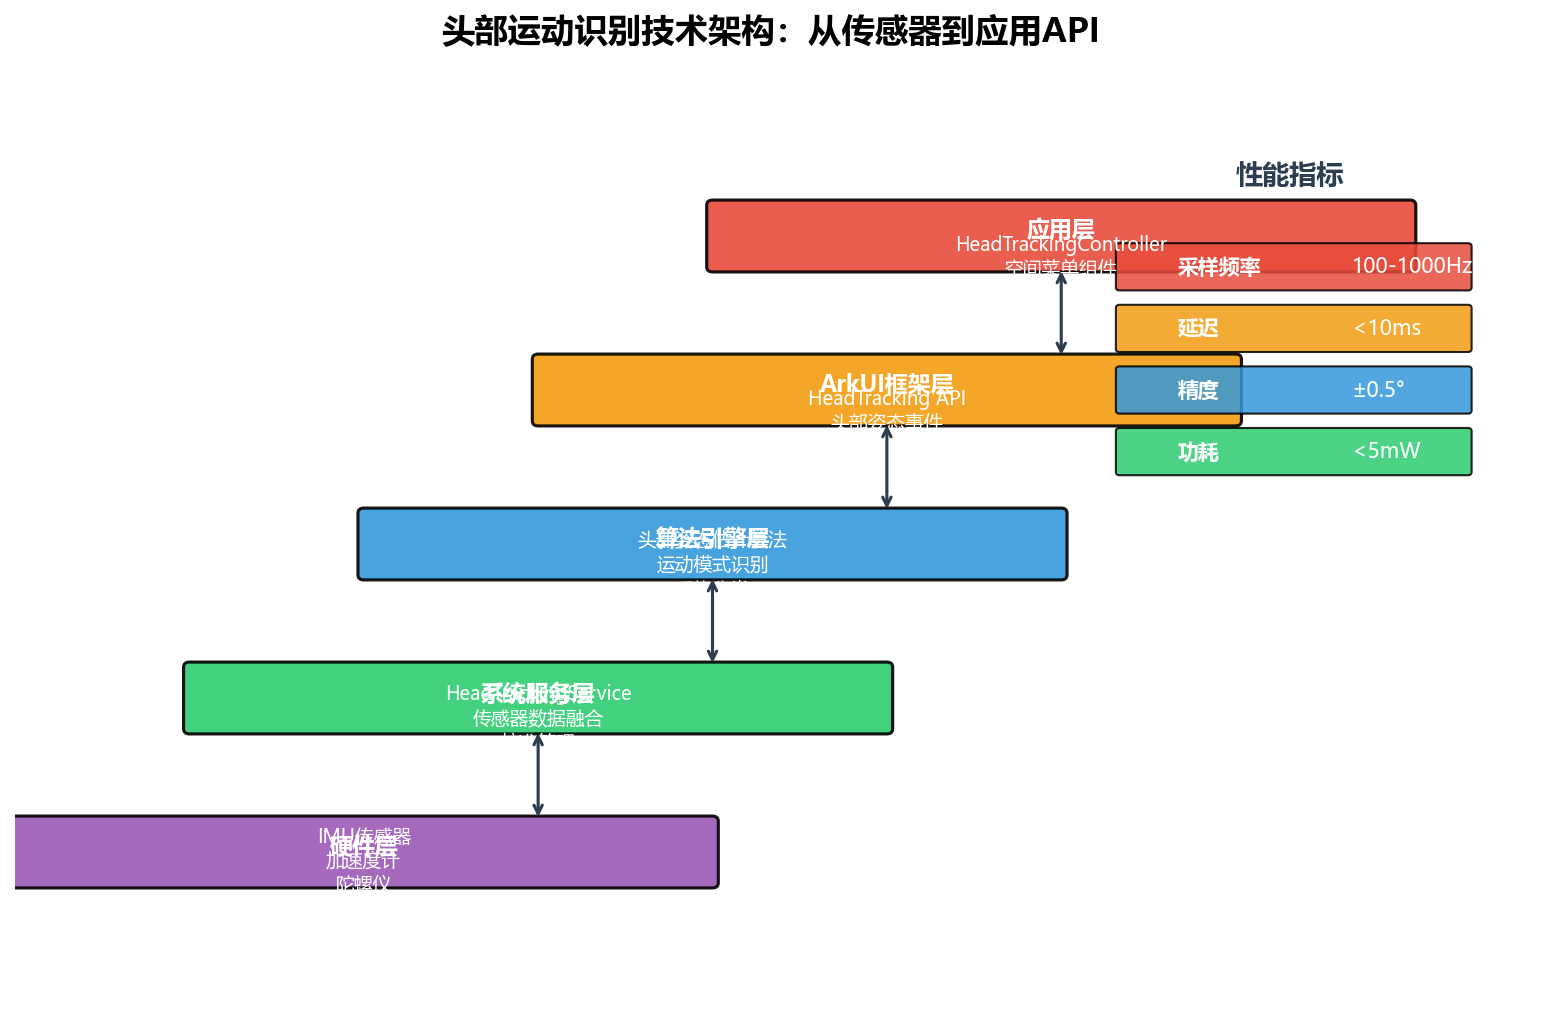
图5:头部运动识别五层技术架构——从IMU传感器到应用API的完整链路
6.1 技术架构
| 层级 | 核心组件 | 关键能力 |
|---|---|---|
| 硬件层 | IMU传感器(加速度计+陀螺仪+磁力计) | 数据采集 |
| 系统服务层 | HeadTrackingService | 传感器数据融合、校准管理 |
| 算法引擎层 | 头部姿态估计算法 | 6DoF姿态计算、运动模式识别 |
| ArkUI框架层 | HeadTracking API | 头部姿态事件、运动模式回调 |
| 应用层 | HeadTrackingController | 头部运动导航组件 |
6.2 性能优化
// 头部运动追踪性能优化配置
const HeadTrackingOptimization = {
  // 采样频率
  sampleRate: 100,  // Hz,平衡精度与功耗

  // 滤波配置
  filter: {
    type: 'complementary',  // 互补滤波
    alpha: 0.98,           // 陀螺仪权重
    beta: 0.02             // 加速度计权重
  },

  // 运动检测阈值
  thresholds: {
    nodAngle: 15,          // 点头角度阈值(度)
    shakeAngle: 15,        // 摇头角度阈值(度)
    tiltAngle: 20,         // 歪头角度阈值(度)
    holdTime: 500          // 保持时间阈值(ms)
  },

  // 功耗优化
  powerOptimization: {
    lowPowerMode: true,    // 低功耗模式
    batchProcessing: true, // 批量处理
    sensorFusion: true    // 传感器融合
  }
};
七、结语:头部是最自然的"遥控器"
HarmonyOS 7(API 26)的头部运动追踪能力,让我们离"自然交互"更近了一步。从手指到头部,交互的维度在扩展,但设计的本质没有变——让技术服务于人,而不是让人适应技术。
作为一名讲师,我希望学生记住的不是API的参数列表,而是一个更根本的设计理念:好的交互设计是隐形的,而头部运动是隐形的极致。
当你的用户转动头部时,系统已经知道他想做什么;当他点头时,系统已经执行了他的意图。这种"未动先知"的体验,才是空间交互的终极追求。
转载自:https://blog.csdn.net/u014727709/article/details/164304612
欢迎 👍点赞✍评论⭐收藏,欢迎指正

作为“人工智能6S店”的官方数字引擎,为AI开发者与企业提供一个覆盖软硬件全栈、一站式门户。
更多推荐
 4
 0
- 0


 已为社区贡献160条内容

所有评论(0)